

LABORXLABORX INDUSTRIAL EMBODIED INTELLIGENCE
Embodied intelligence for real industrial work.
Backed by LK Technology
Product matrix
Scroll to explore mobile robots and dexterous manipulation platforms.
01 · 人形机器人
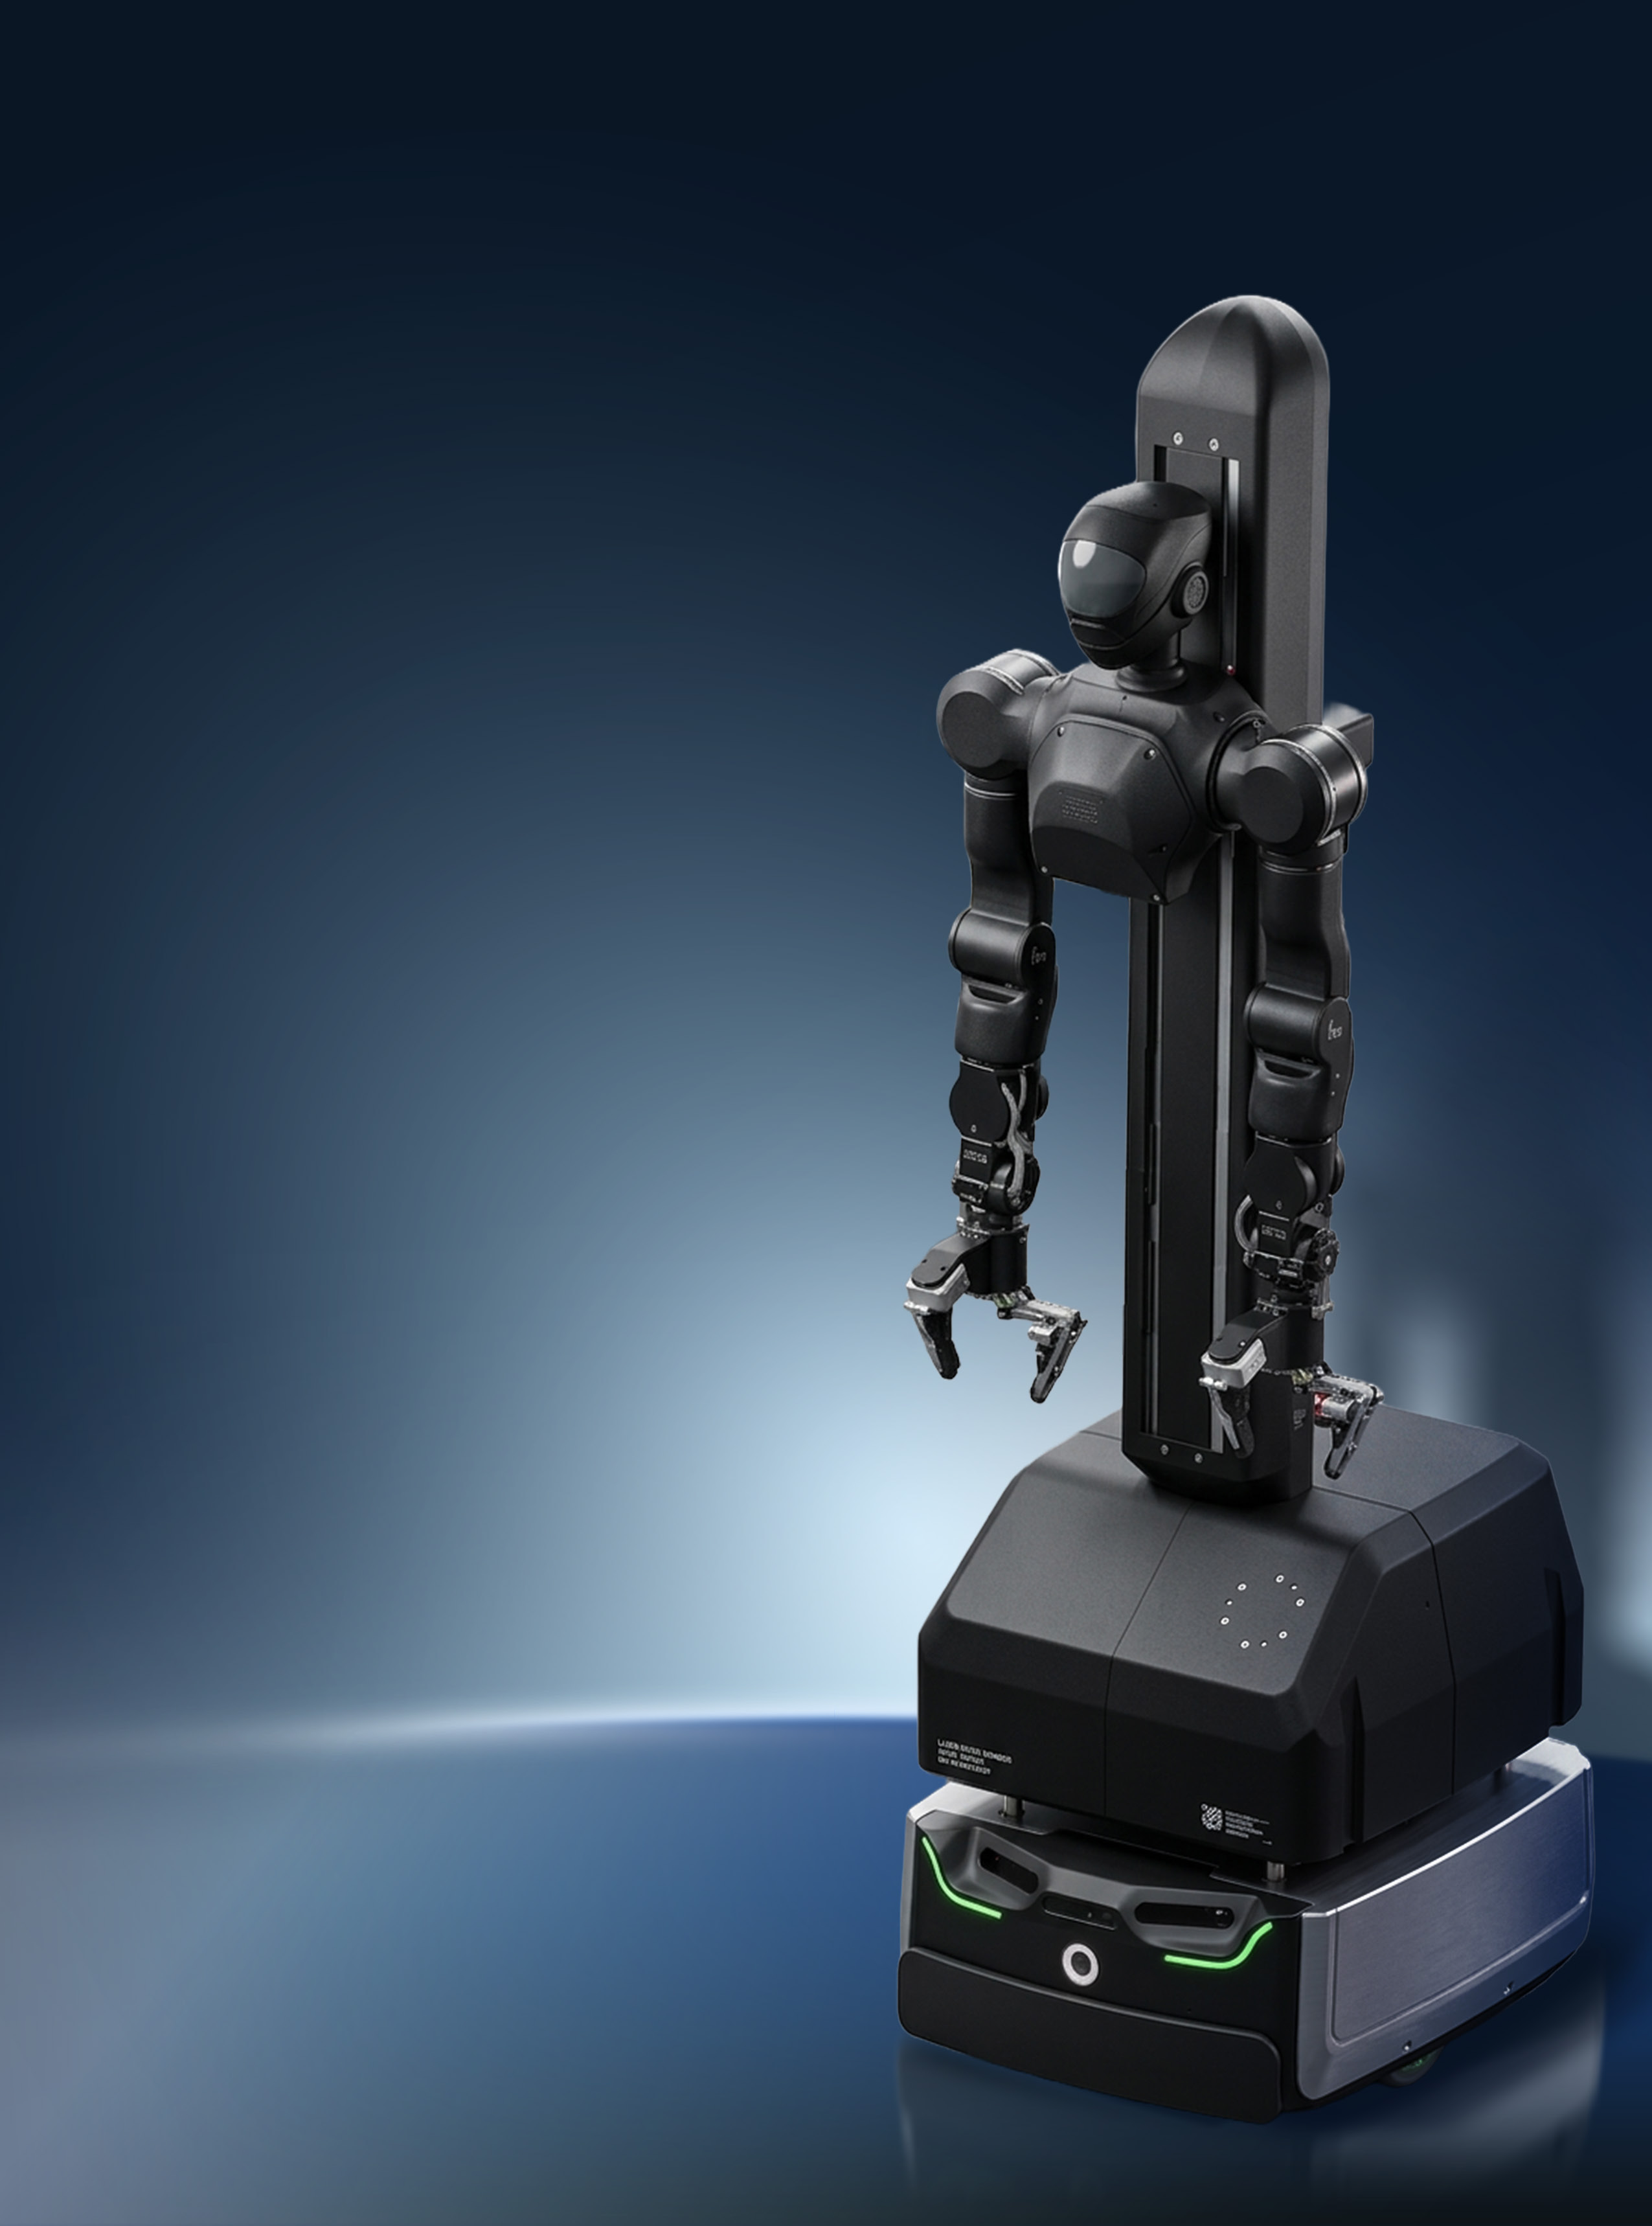
M1 Wheeled Dual-arm Robot
M1 integrates an omnidirectional mobile base, an 800 mm lift, dual-arm manipulation and multi-camera perception into one platform for compound tasks in industry, research and service settings.
View product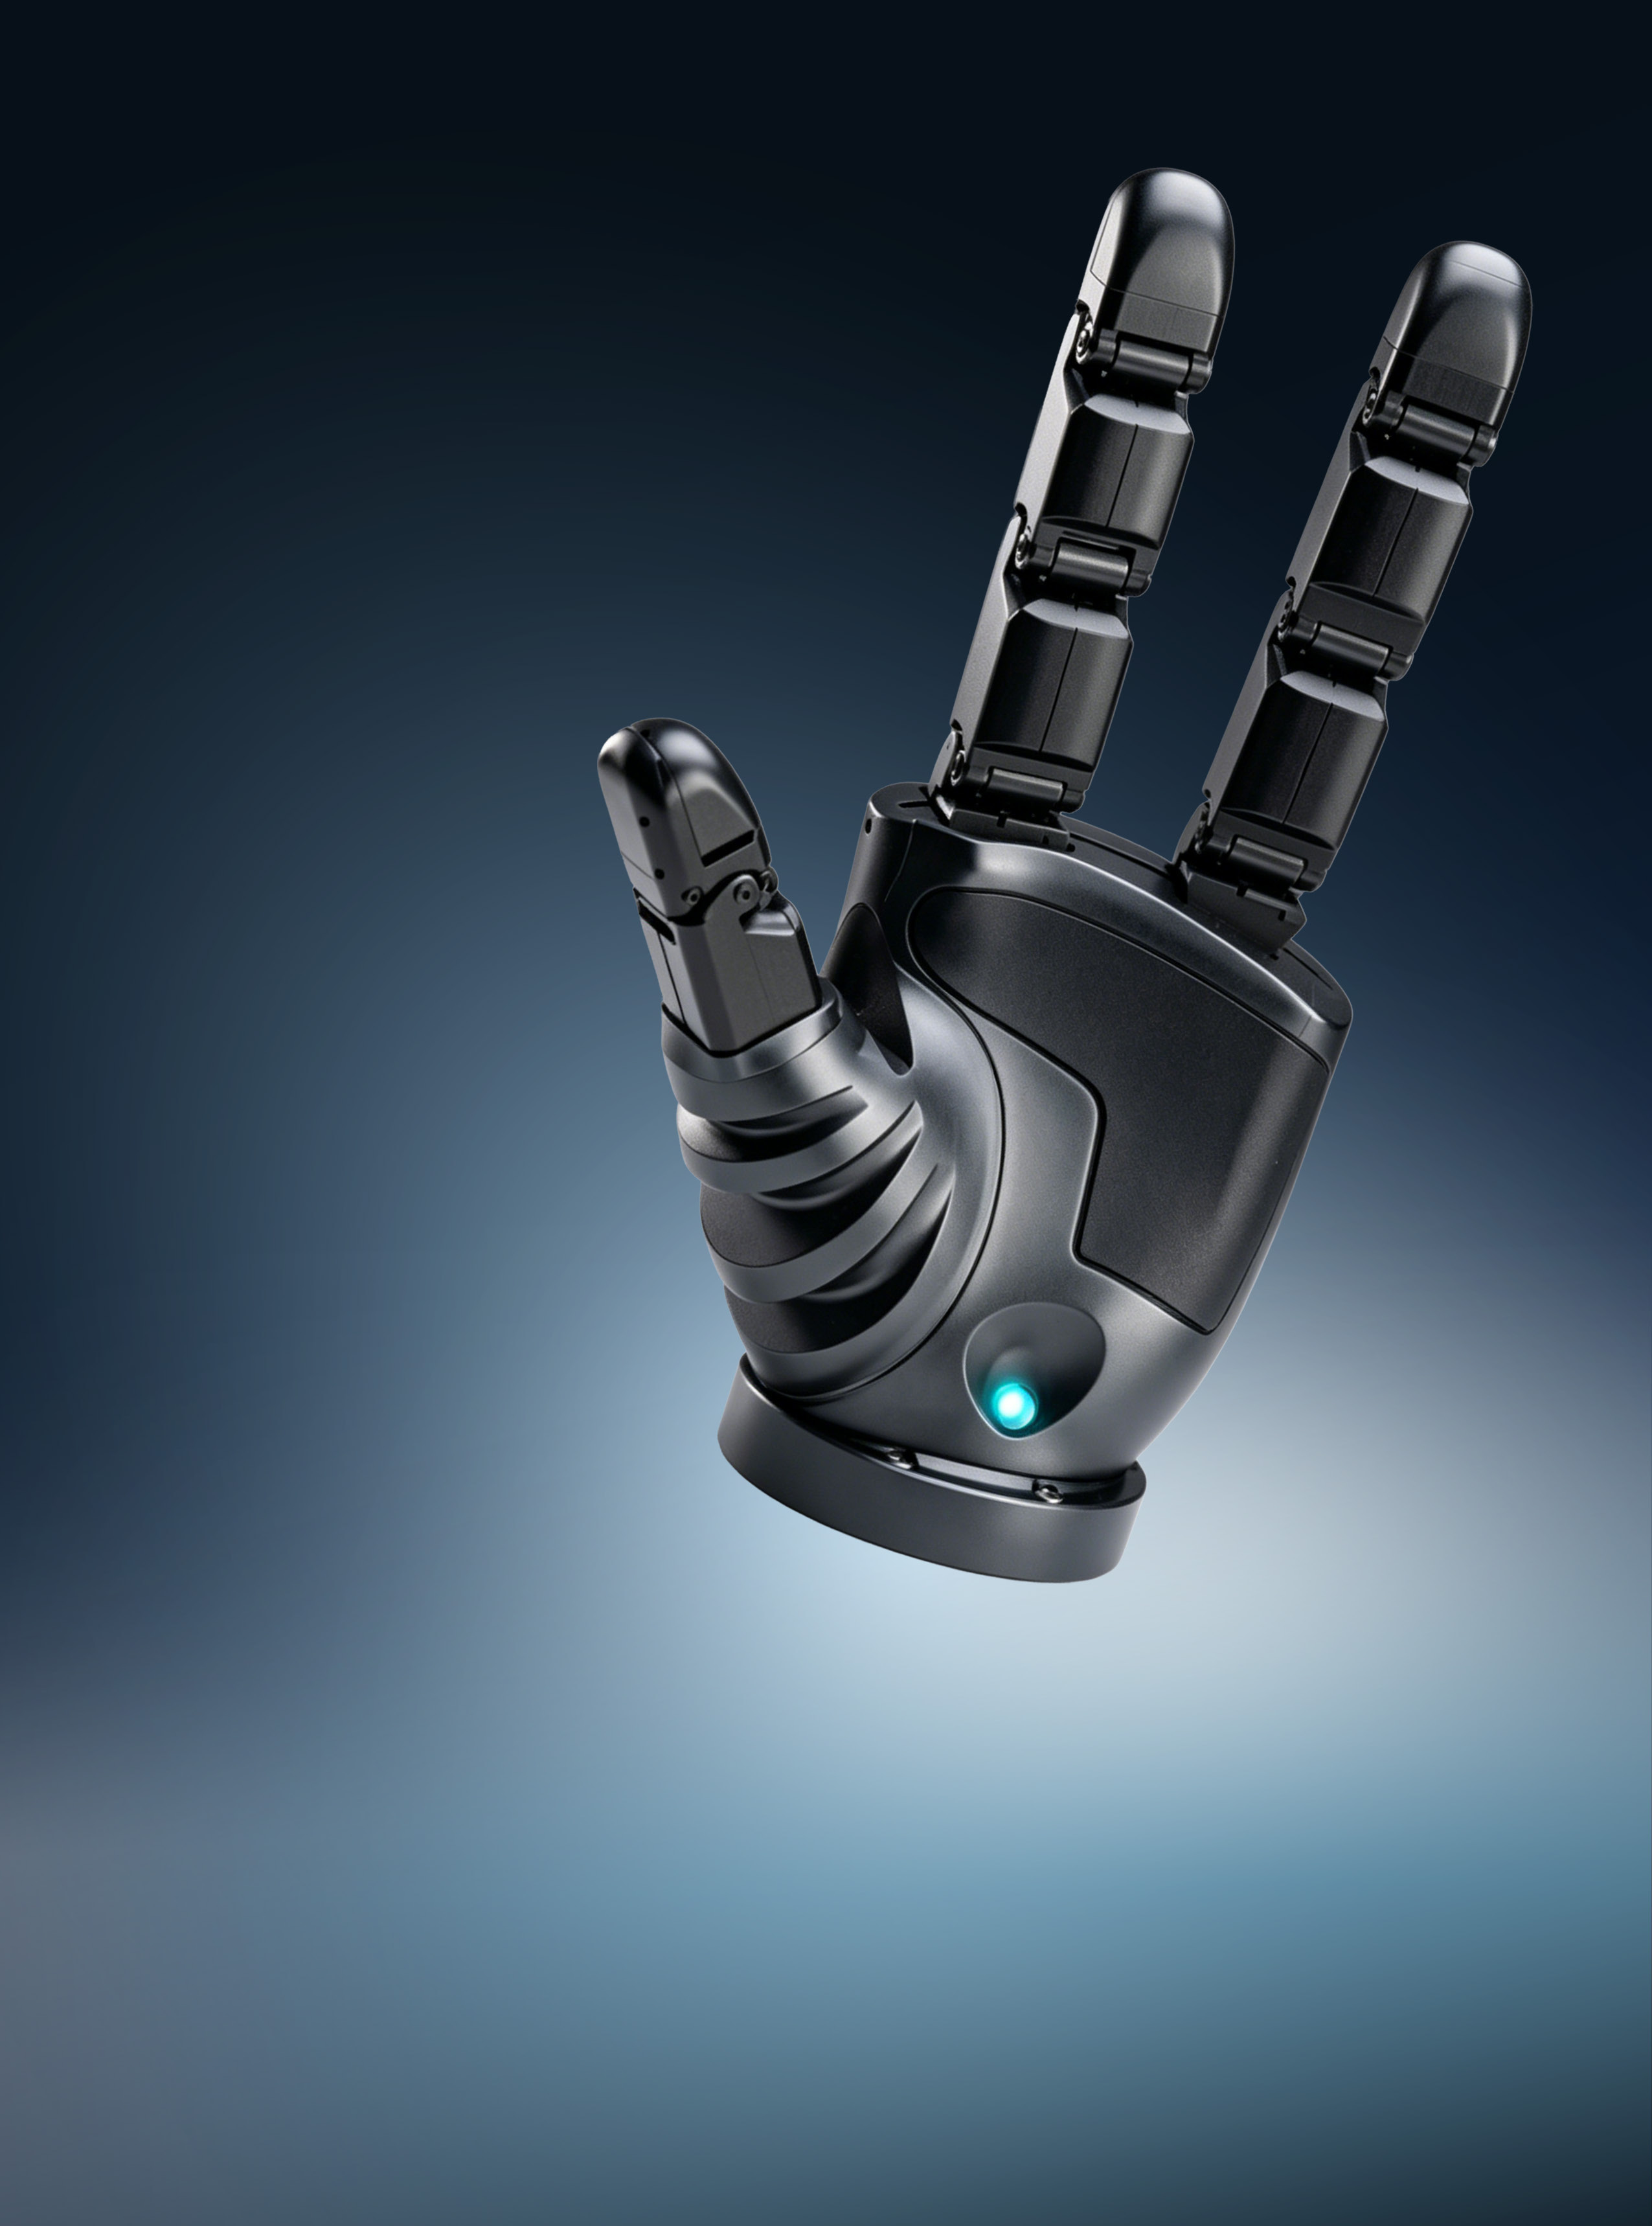
02 · 灵巧手
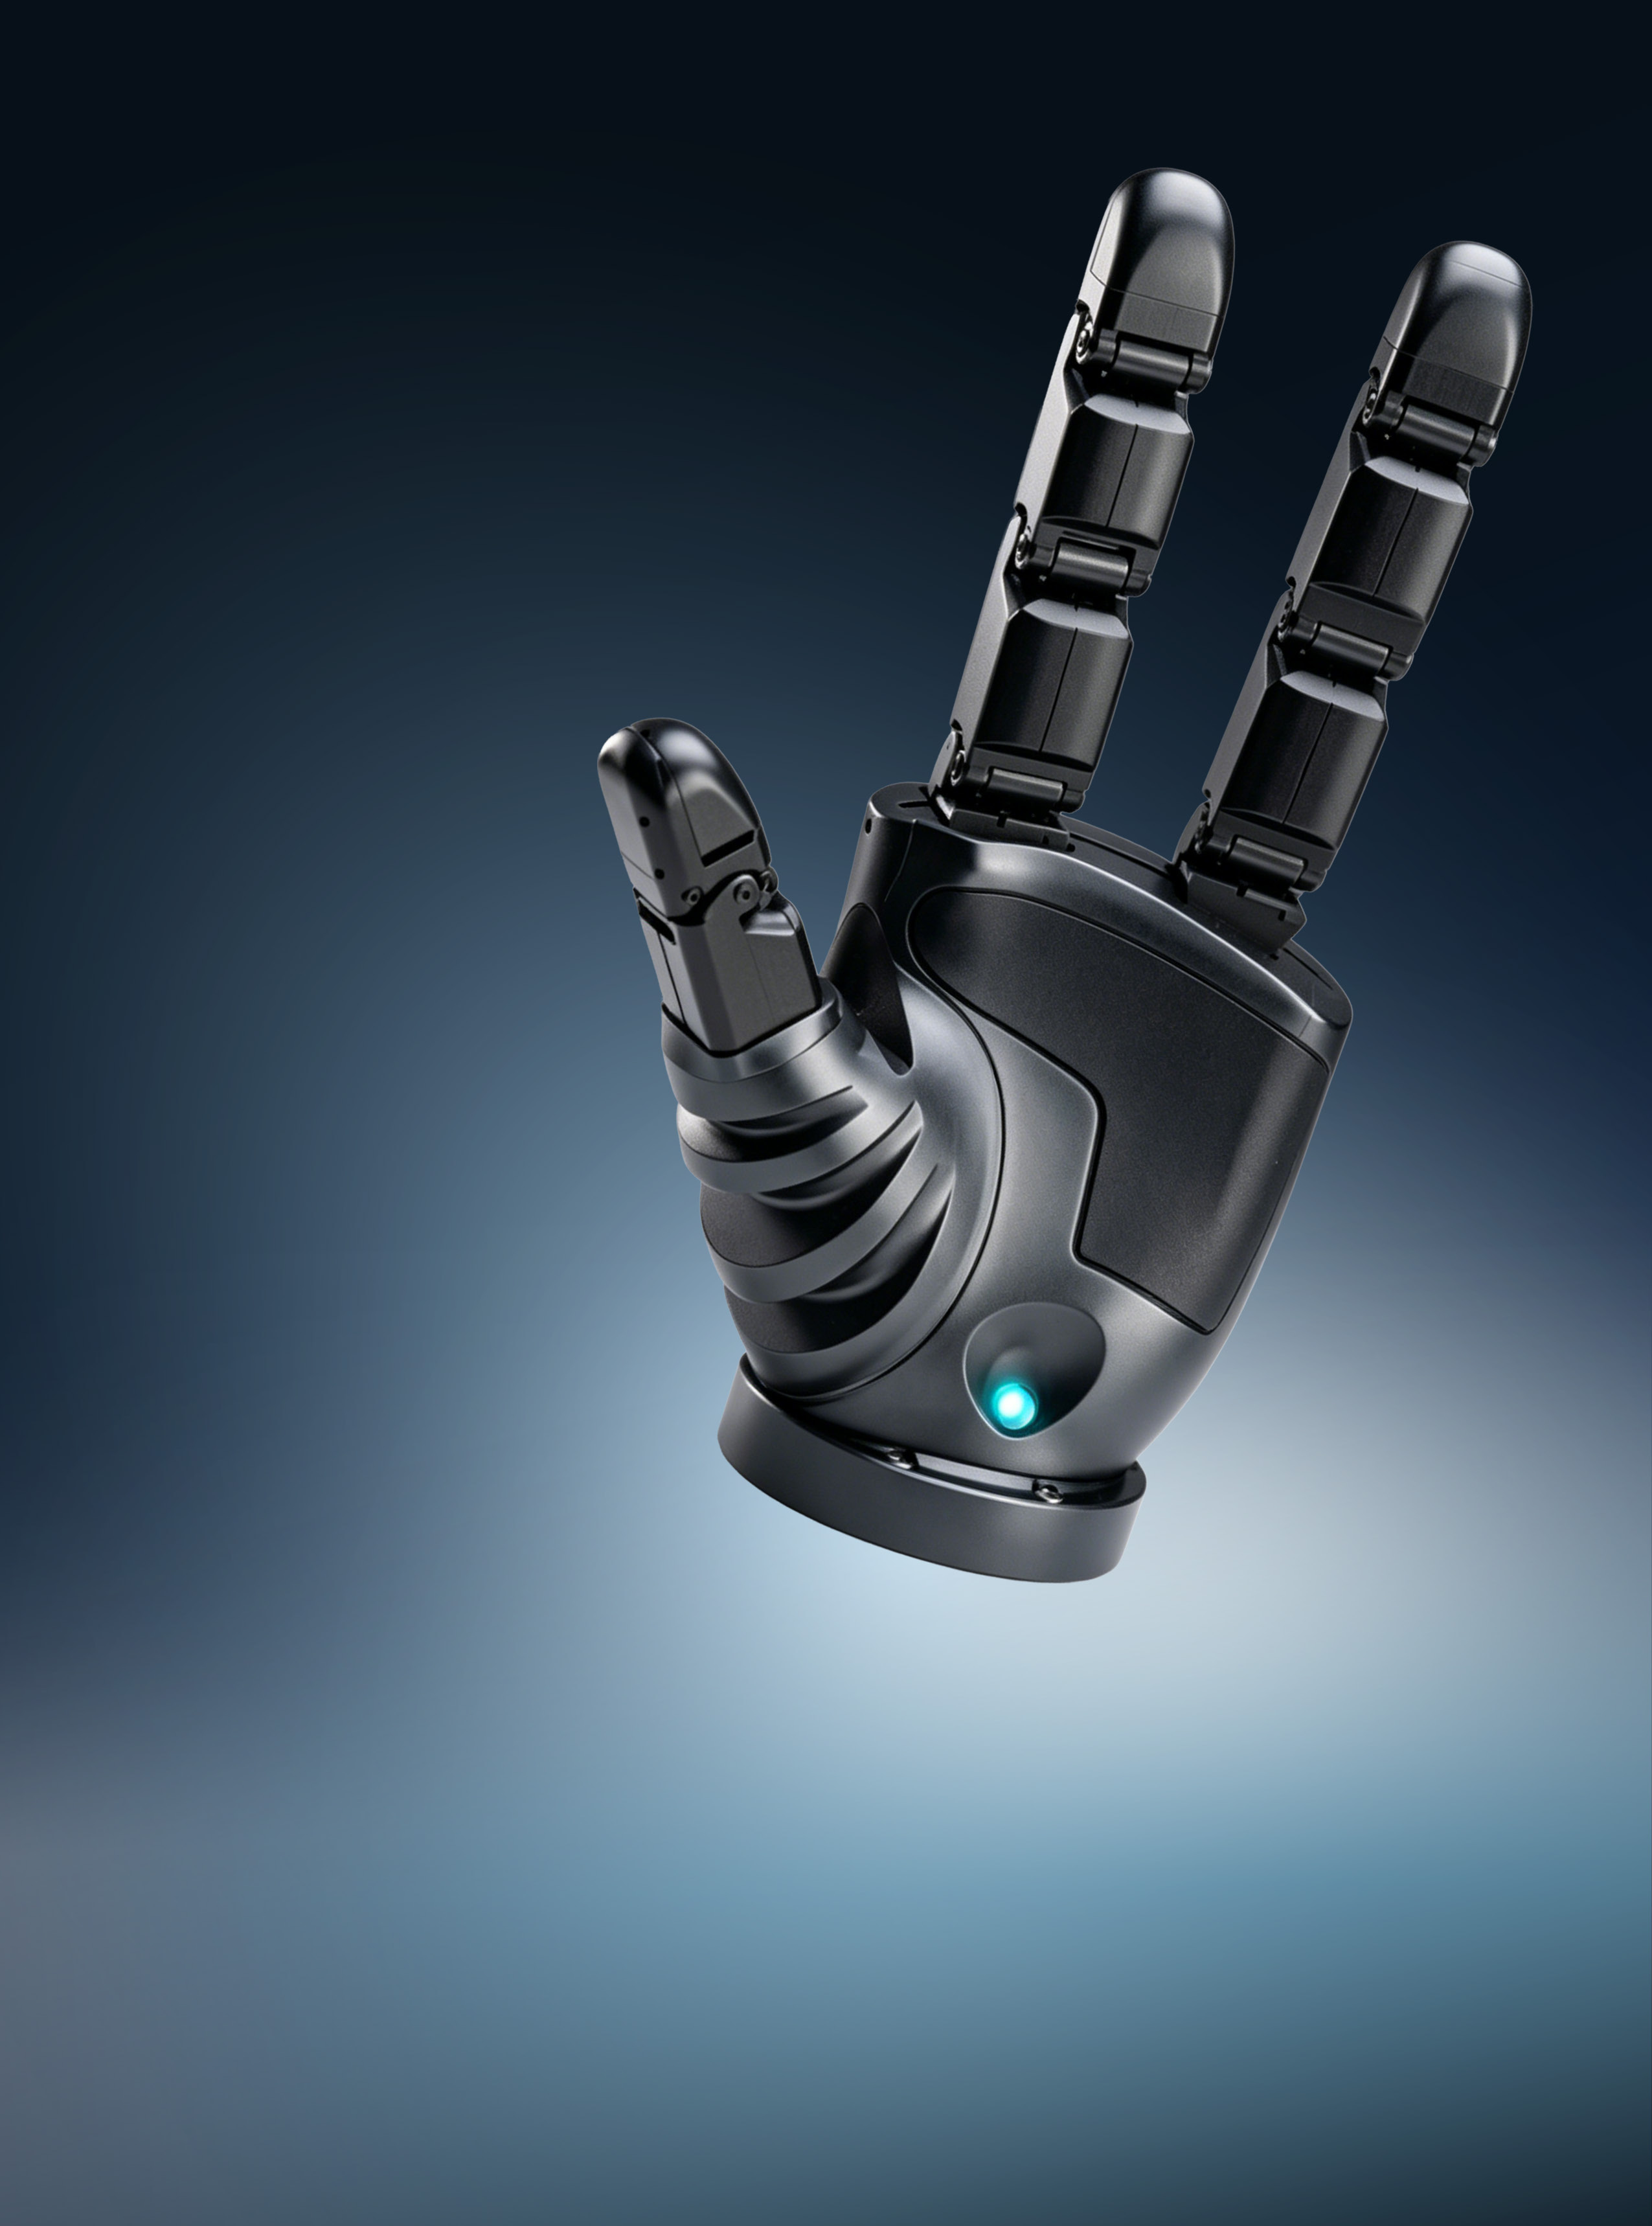
Three-finger Fully Actuated Force-control Hand
Twelve degrees of freedom work with a three-layer force-control loop in a compact body for precision pinching, planar clamping, opposed grasping, side clamping and precision insertion.
View product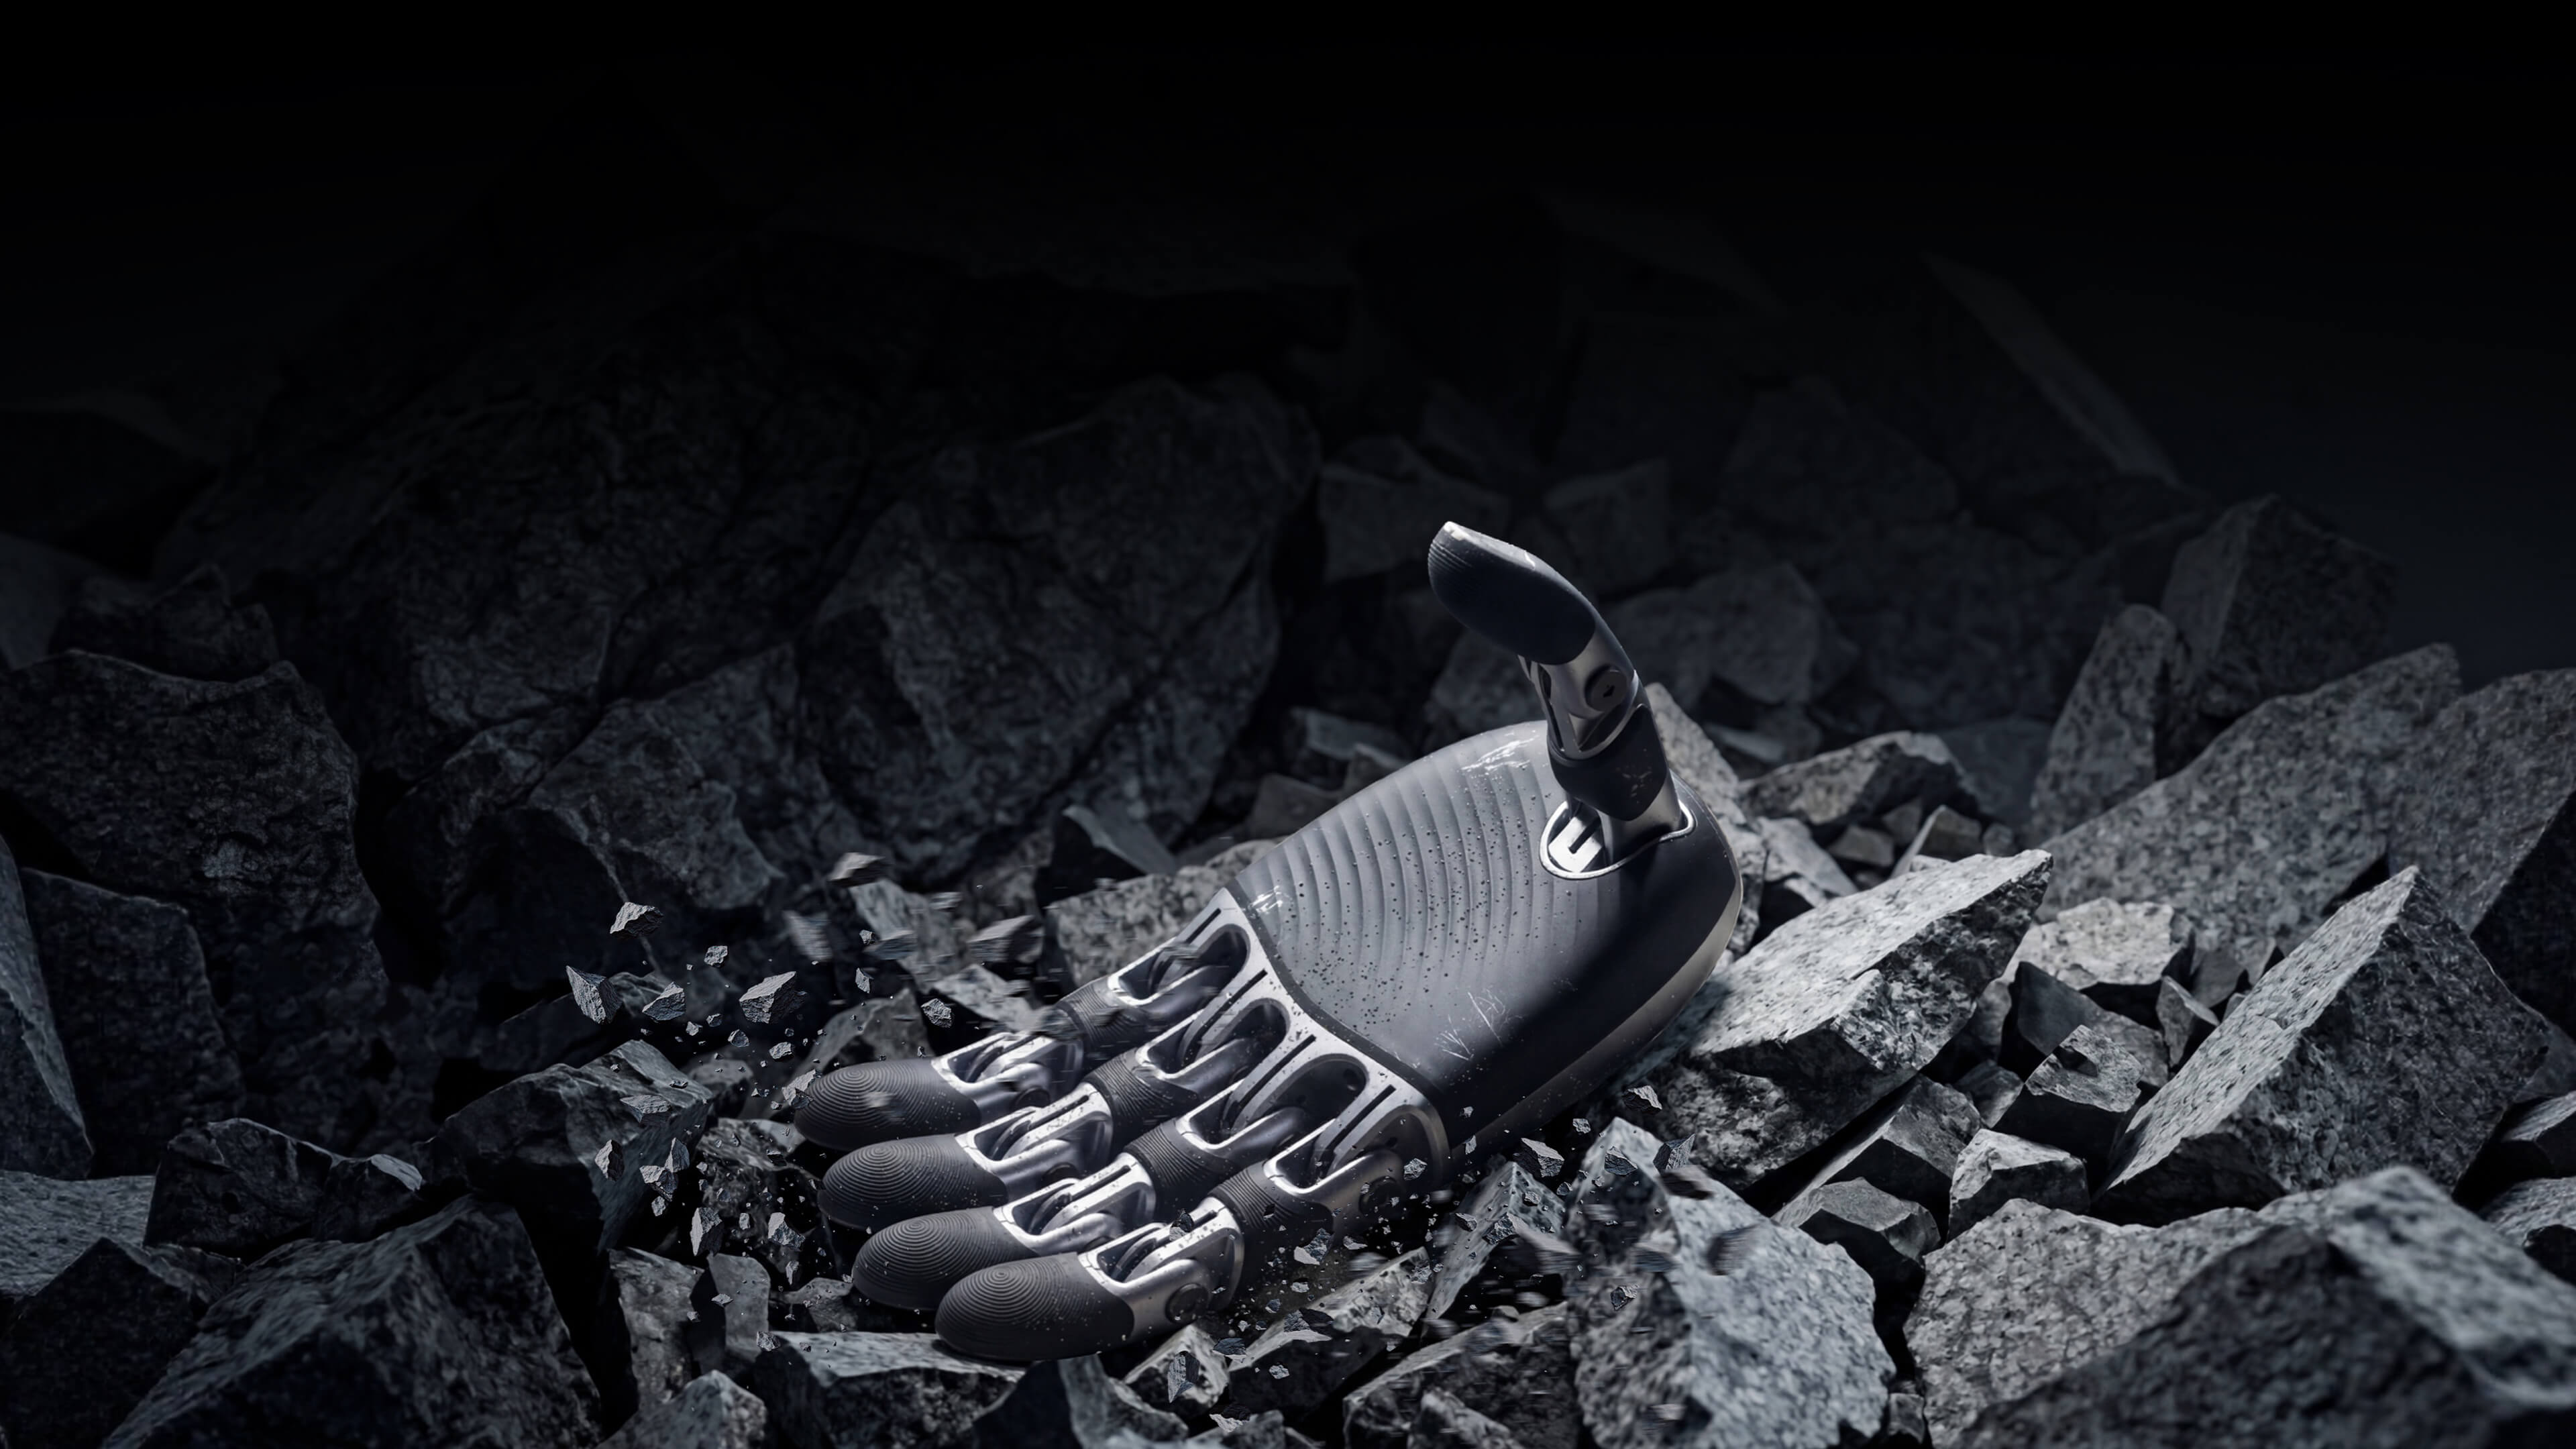
03 · 灵巧手
Five-finger Fully Actuated Force-control Hand
Four parallel grasping fingers and one opposed thumb create a natural anthropomorphic workspace, built around twenty DOFs, multimodal tactile sensing and real-time software interfaces.
View product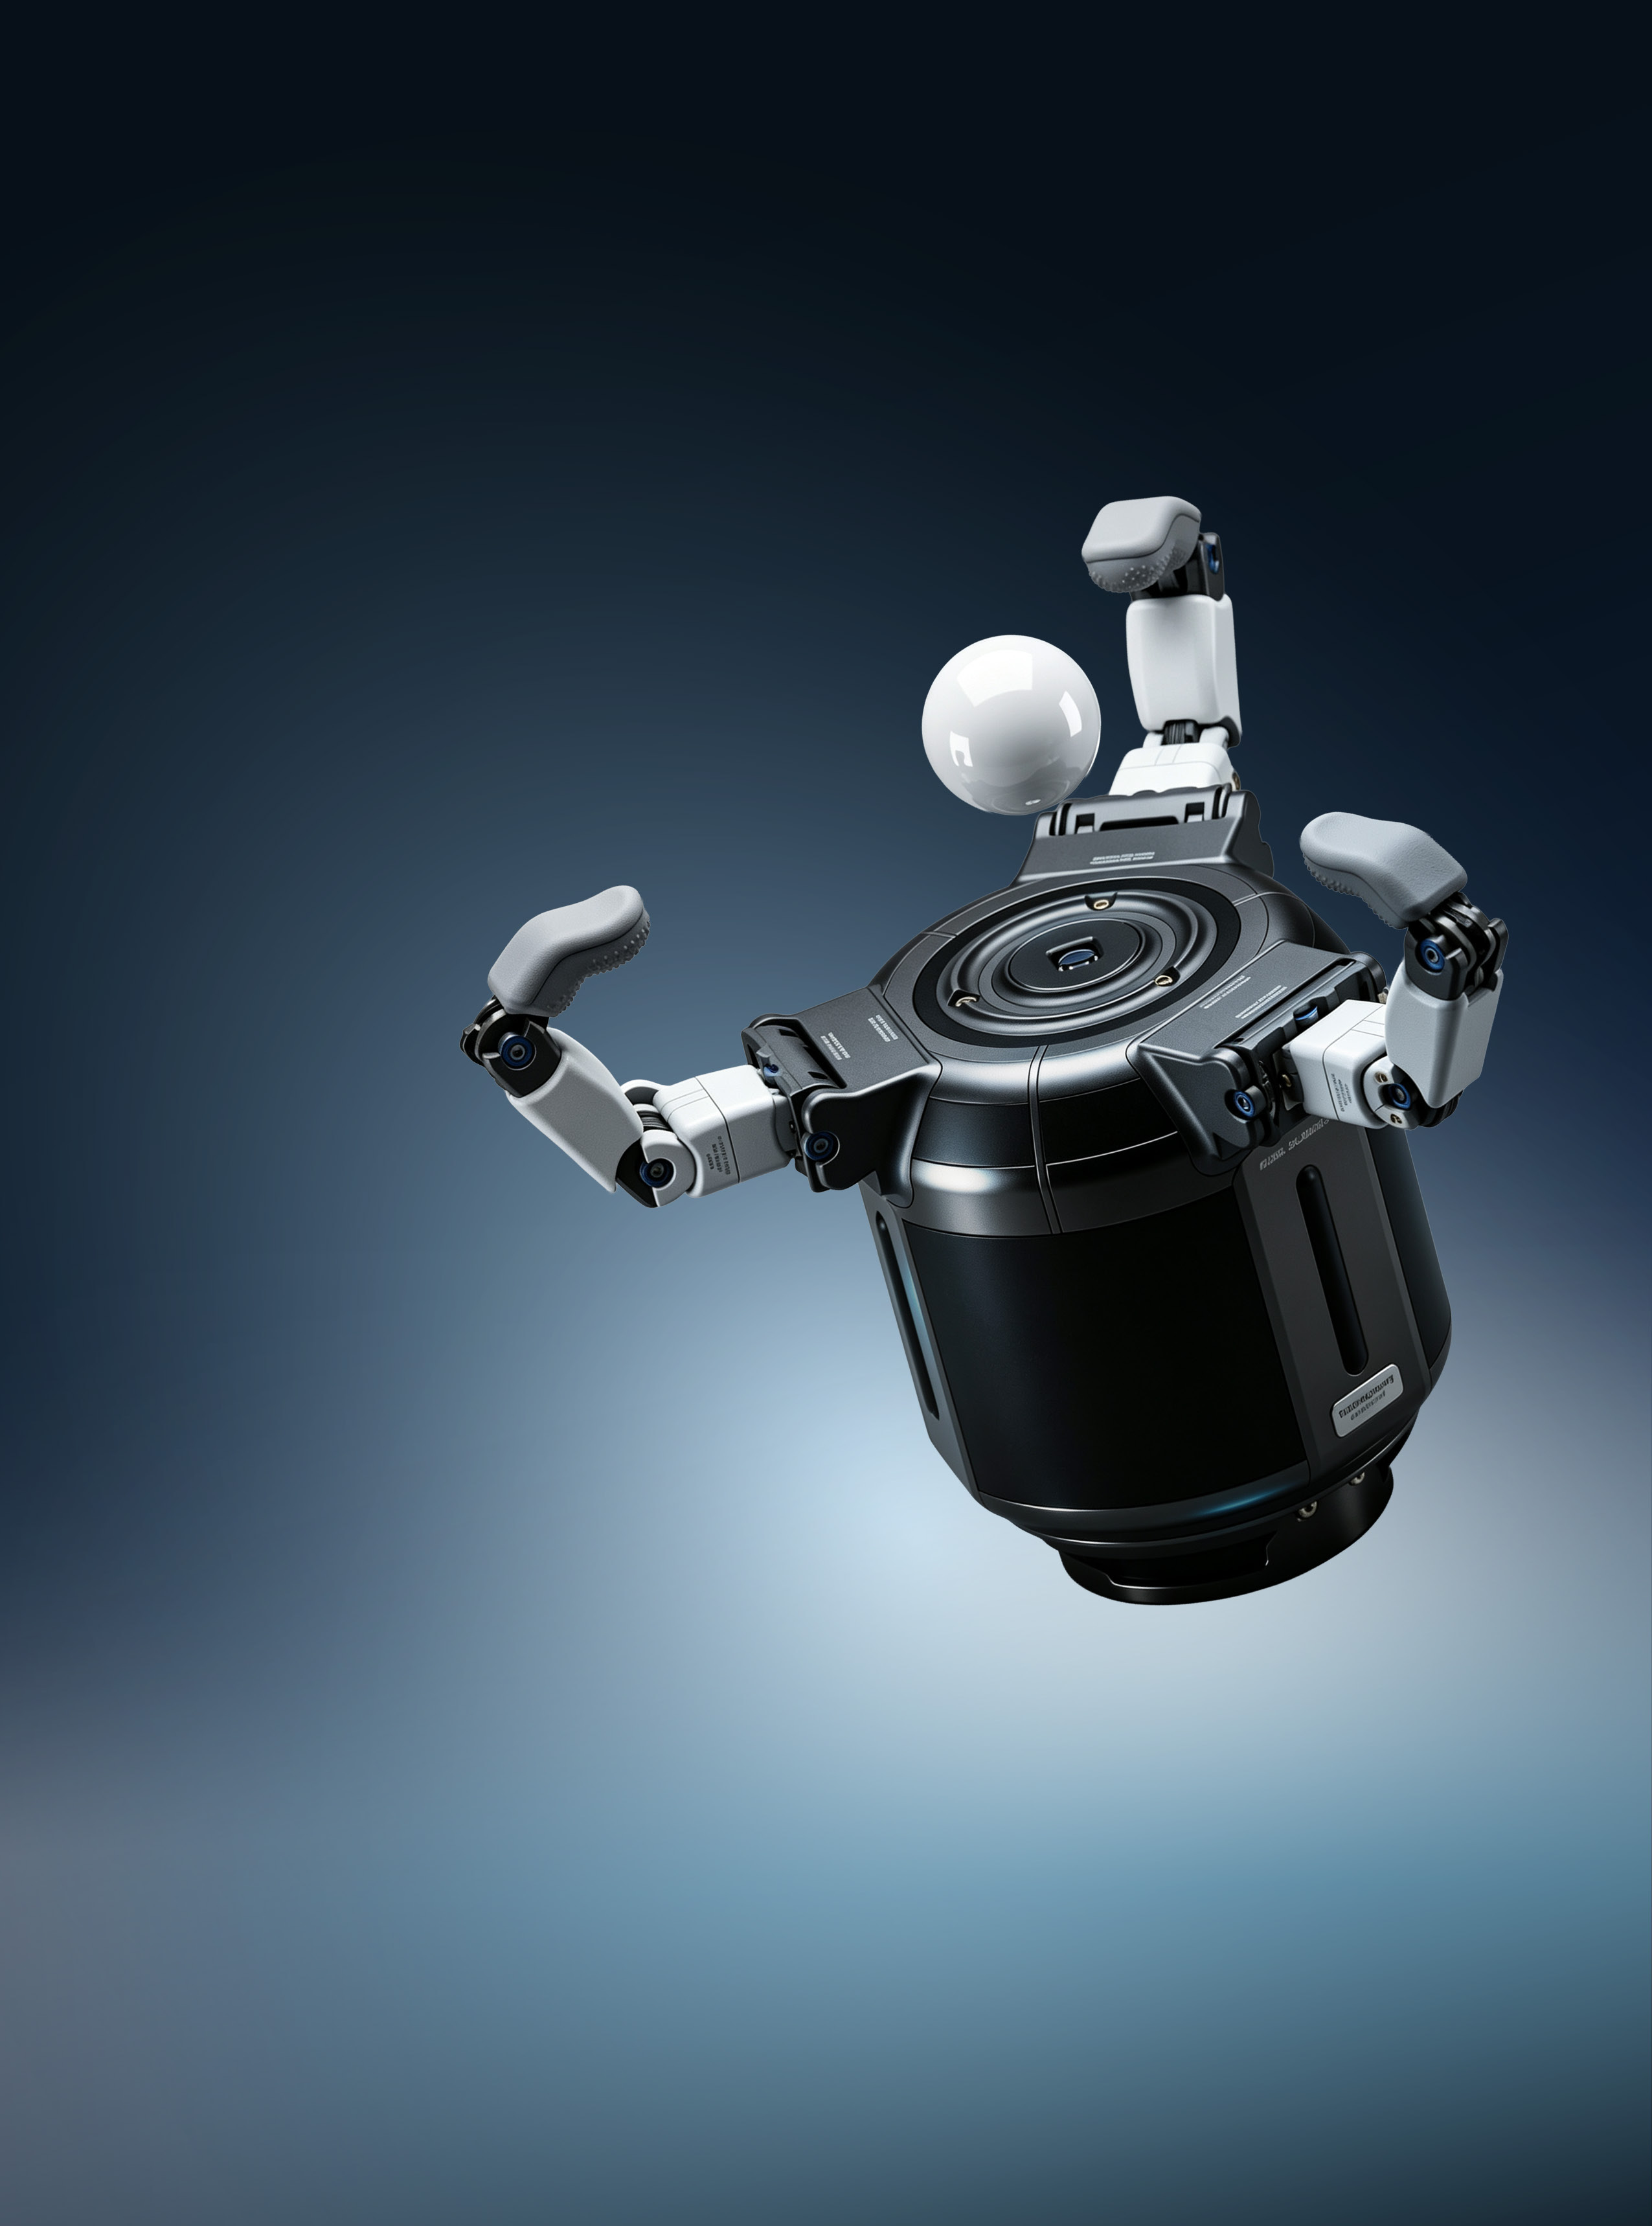
04 · 灵巧手
Three-finger Tendon-driven Dexterous Hand
A symmetric 120° three-finger layout with three joints and four DOFs per finger balances multi-DOF motion and flexible grasping through tendon drive.
View productAPPLICATIONS
All applications From capability to real tasks.
Robot applications must be assessed against the workpiece, cycle time, space and safety requirements. These scenarios demonstrate current product capabilities.
01 / 工业制造
3C 电子精密装配
结合双臂操作、精密定位与力控末端,支持插装、抓取与上下料等复合流程。
M1 + 三指全驱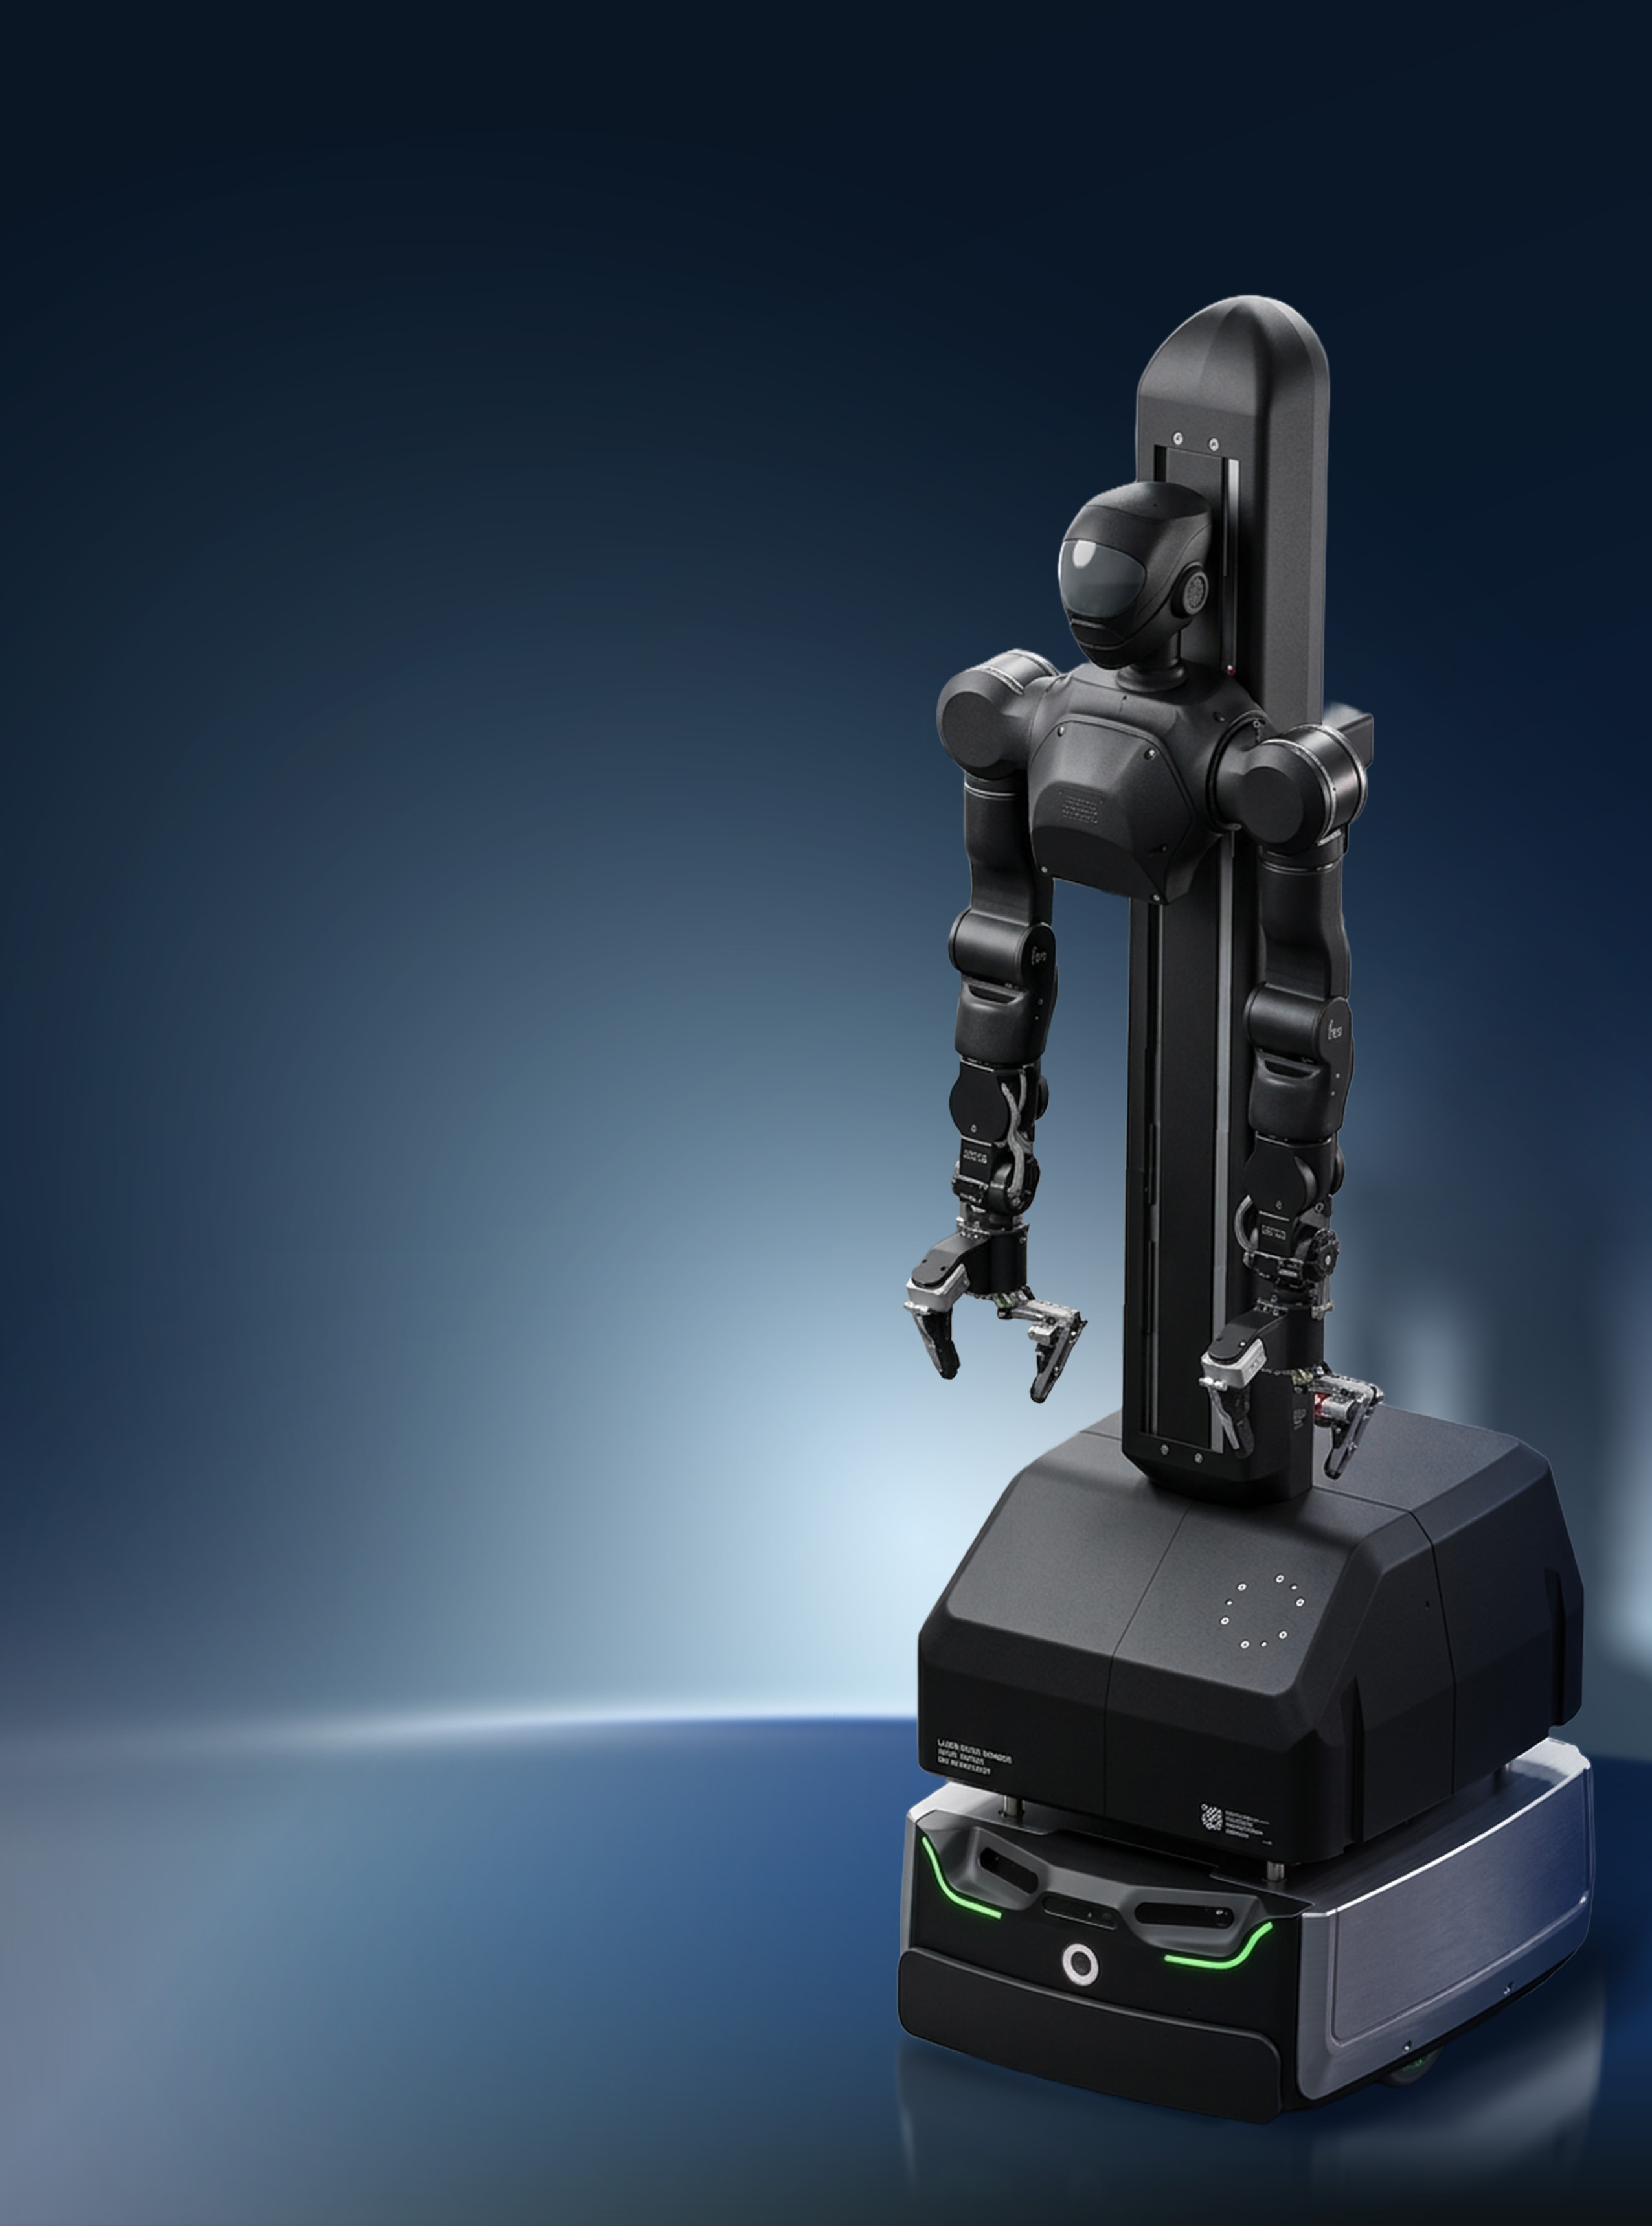
02 / 工业制造
汽车零部件装配
移动到目标工位后完成零件抓取、搬运与协同装配,适配柔性生产节拍。
M103 / 物流仓储
货架补货与订单拣选
通过自主移动、环境感知和双臂操作完成多工位物流任务。
M1Application content is a capability-based demo. Specific operating conditions require technical assessment.